ICL at IROS 2026
The Intelligent Control Lab joined the robotics community at IROS 2026 with four papers, the RoCo Challenge, a creativity workshop, and live demonstrations spanning bimanual assembly, bimanual sanding, and AI tutoring.
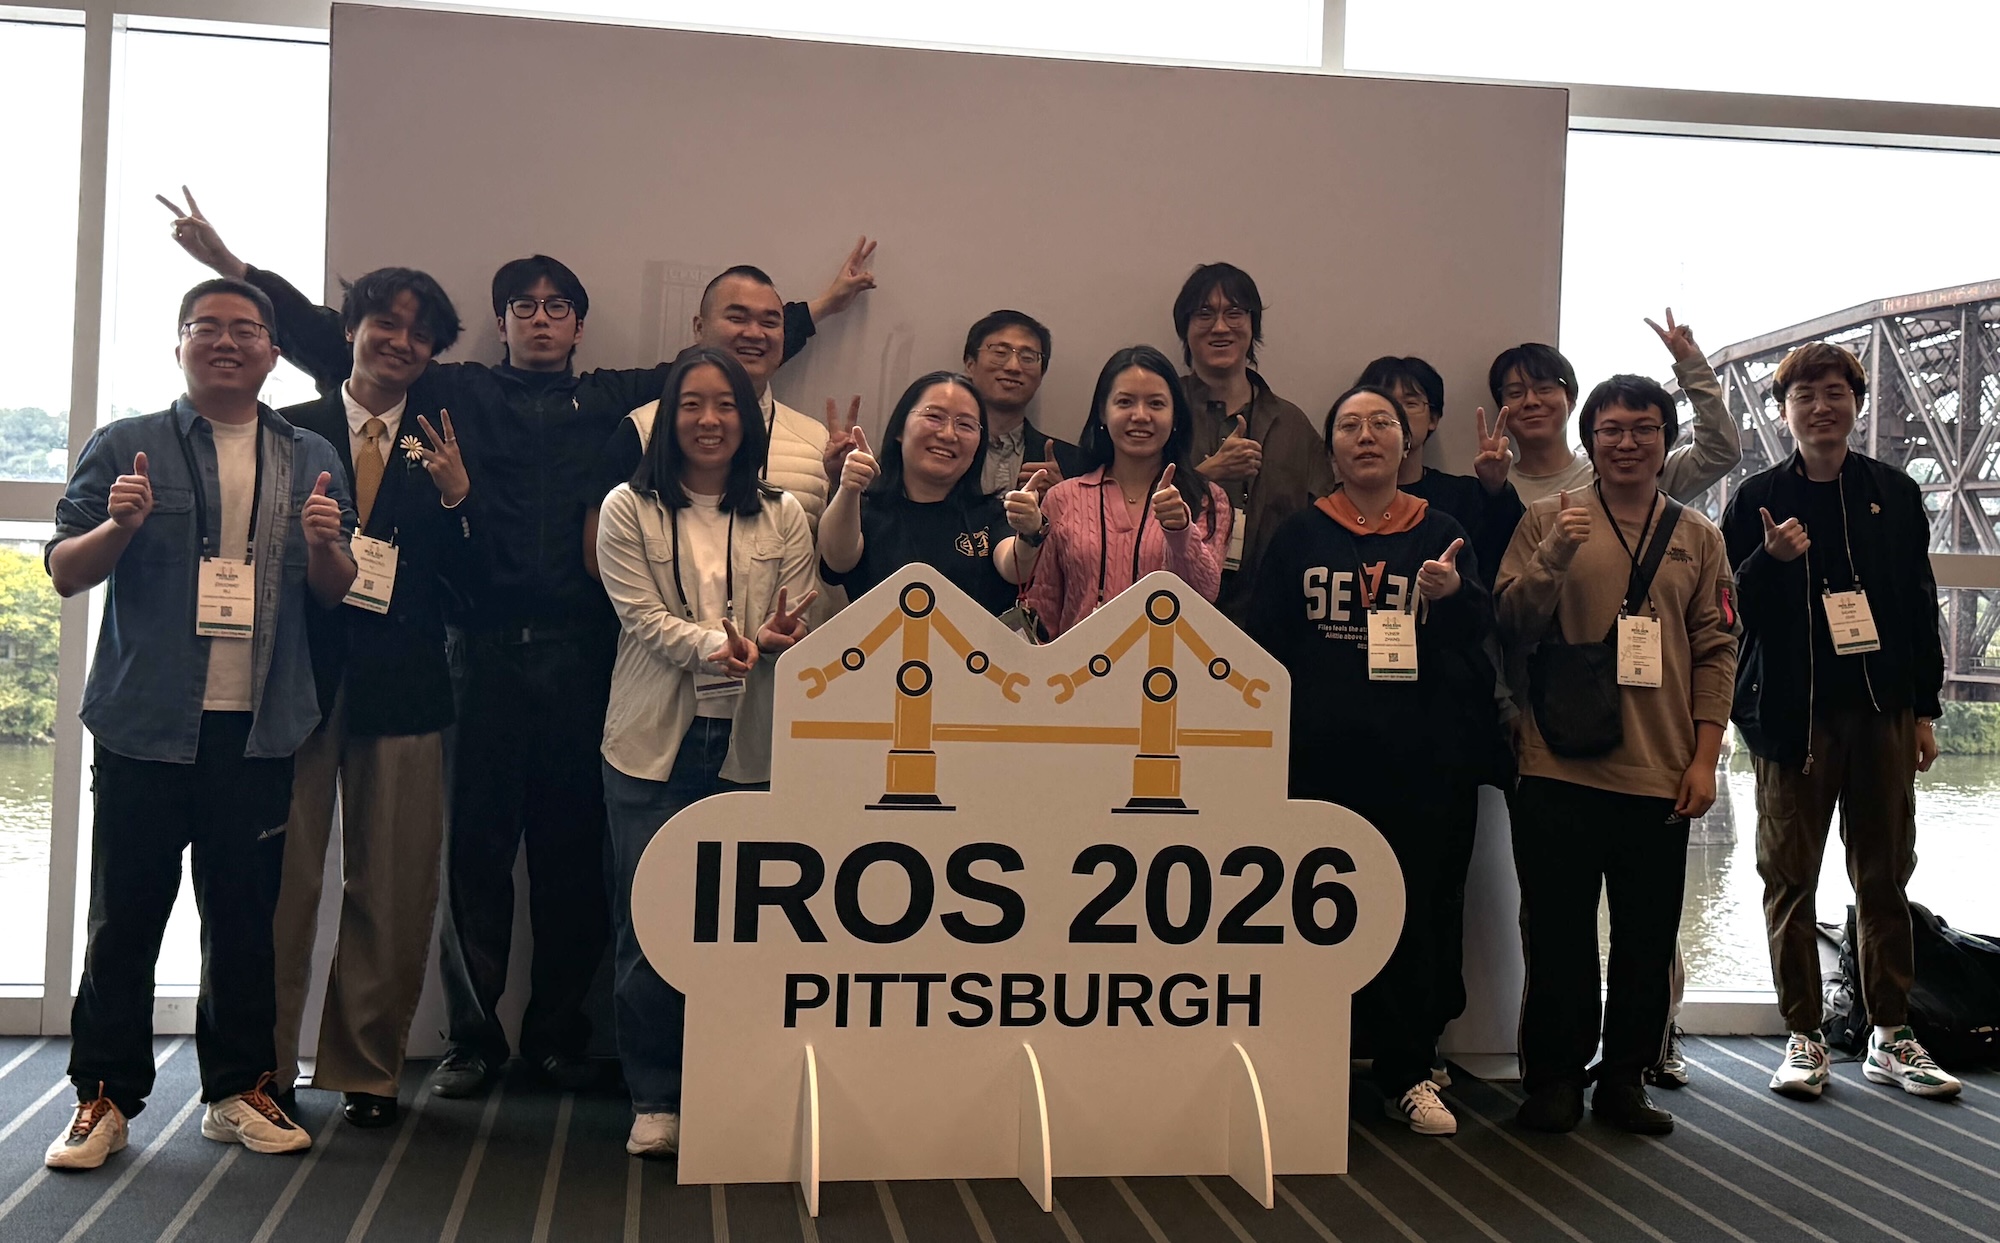
Four papers presented at IROS
Our team presented four papers at the conference:
-
[C115] Learning Safe-Stoppability Monitors for Humanoid Robots
Yifan Sun, Yiyuan Pan, Shangtao Li, Caiwu Ding, Tao Cui, Lingyun Wang and Changliu Liu
IEEE/RSJ International Conference on Intelligent Robots and Systems, 2026
-
[C116] Motion Planning with Model-Based Diffusion via Constraint Optimization and Adaptive Scheduling
Zhilin He, Bowei Li, Jianlin Dou, Yuner Zhang and Changliu Liu
IEEE/RSJ International Conference on Intelligent Robots and Systems, 2026
-
[J41] Prompt-to-Product: Generative Assembly via Bimanual Manipulation
Ruixuan Liu, Philip Huang, Ava Pun, Kangle Deng, Shobhit Aggarwal, Zhenran Tang, Michelle Liu, Deva Ramanan, Jun-Yan Zhu, Jiaoyang Li and Changliu Liu
IEEE Robotics and Automation Magazine, 2026
-
[J35] NL2HLTL2Plan: Scaling Up Natural Language Understanding for Multi-Robots Through Hierarchical Temporal Logic Task Specifications
Shaojun Xu, Xusheng Luo, Yutong Huang, Letian Leng, Ruixuan Liu and Changliu Liu
IEEE Robotics and Automation Letters, 2025
The Robotics Institute also featured our humanoid safety work in “Knowing Their Limits”.
RoCo Challenge
ICL organized the RoCo Challenge at IROS, bringing participants together around robot-control tasks.
Creativity in Assembly Workshop
We also organized the Creativity in Assembly Workshop, focused on creative approaches to robotic assembly.
Demonstrations
- Bimanual assembly: Prompt-to-Product demonstration.
- Bimanual finishing:
- ARISTOS: View the demonstration materials.